Used by the teams defining Physical AI
From half-marathon-winning bipeds, to dexterous industrial humanoids, to safe human-robot collaboration in research labs. Xsens Humanoids ground-truth motion data, in production.
Home » Deployments
Case studies and research from the humanoid and robotics teams already training on Xsens Humanoids data.
Visit our facility to see the full capture-to-robot pipeline running live, and test the third-party integrations that plug into the Xsens stack.
Public videos showing what humanoid training looks like in practice from teleoperation to dexterous task transfer to keynote-stage demos.
Humanoid programs in production
Example cases of customers deploying Xsens in real humanoid programs.
Winning the Beijing Humanoid Half-Marathon
Tiangong 1.2 Max won the 2025 Beijing Humanoid Half-Marathon, running 21.1 km across real-world terrain. The robot was trained on human movement data, captured with Xsens Humanoid motion capture software, producing more natural gait, real-time balance adjustments and energy-efficient joint coordination. During the race, an MTi-630 IMU at the pelvis delivered orientation and acceleration data at 400 Hz for millisecond-level terrain response.
Outcome: 1st place, full 21.1 km finish, real-world bipedal locomotion under race conditions.
Teaching humanoids how to move like humans
Shanghai Humanoid selected Xsens motion capture as the only inertial system without data-drift issues for industrial training. By combining capture with AI training, their robots learned dexterous tasks like sorting red beans from soybeans through teleoperation and human shadowing. The setup scales: multiple operators capture in parallel, feeding rich, diverse data into model training across factory environments.
Outcome: production-grade dexterous manipulation training, multi-operator scaling.
Adaptive collaborative interface for safe human-robot interaction
IIT’s Human-Robot Interaction Lab used Xsens motion data to help a robot understand what a person is about to do. After three months of training, it predicted moves like pushing and pulling with 98% accuracy. People carrying objects together with the robot finished faster and with less effort, showing that motion data is what makes safe human-robot teamwork possible.
Outcome: 98% intent-prediction accuracy. Faster, lower-effort collaborative tasks.
Humanoid training in action with Kepler Robotics
A short film showing Xsens-humanoids motion capture inside the Kepler Robotics humanoid training loop: operator captures human demonstration, motion is retargeted, the robot repeats it. The clearest look at what training data actually looks like in a humanoid pipeline.
Outcome: Xsens motion data set the training reference for Kepler’s next scale-up project
View Humanoid Training in Action
Public videos that show what humanoid training looks like from teleoperation to dexterous task transfer to keynote-stage demos.
Boston Dynamics: humanoid teleoperation
Field demonstration of teleoperated humanoid manipulation, queued to the operator-control segment.
Humanoid factory-floor demonstration
An industrial humanoid running task demonstrations on a real production floor.
NVIDIA: Physical AI keynote, humanoid segment
The humanoid training portion of the NVIDIA physical-AI keynote, queued past the intro.
Dexterous task transfer
A dexterous manipulation policy transferred from human capture to humanoid execution.
BridgeDP: humanoid teleoperation in the field
A BridgeDP humanoid running teleoperated tasks captured in real working conditions.
Cited in the humanoid science
Research groups working on the unsolved parts of Physical AI use Xsens Humanoids as ground truth. A small selection of the published work below.
Validation of magneto-inertial measurement units for upper-limb motion analysis through an anthropomorphic robot
Validates inertial motion capture accuracy against an anthropomorphic robot reference. A foundational reference for using IMU data as ground truth for upper-limb manipulation training.
Carrying the uncarriable: a deformation-agnostic and human-cooperative framework
Multi-robot collaborative carrying of objects with unknown deformation, using human movement data to bootstrap robot policies. Published by IIT collaborators.
Human-robot collaborative carrying of objects with unknown deformation characteristics
Motion transfer from human operators to humanoid systems for collaborative manipulation under uncertainty about object properties.
Human motion mapping to a robot arm with redundancy resolution
Kinematic data translation for Humanoid control. An early reference work on retargeting human kinematics to redundant robot arms.
A dedicated environment for humanoid robotics
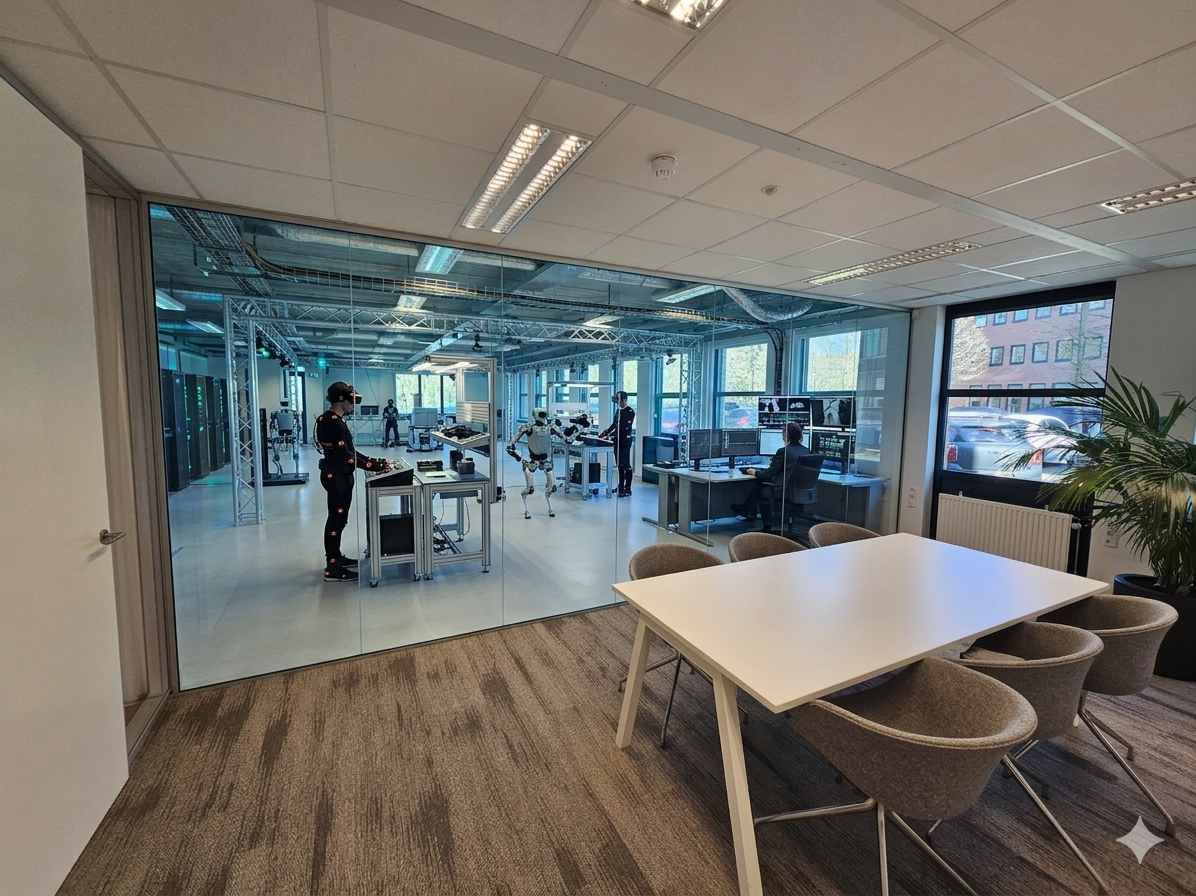
A experience center at Xsens Humanoids HQ in Enschede where you can see live teleoperation, data farming pipelines, retargeting and onboard deployment first-hand, and test the third-party tools that plug into the Xsens stack.
Learn More
If you are training a humanoid program at any scale, talk to the team behind these results.